Research
Publications
People
News
Student Projects
Join Us
Wiki
Contact
Light
Dark
Automatic
Human-Robot Interaction
A Visual-Impedance Teleoperation Framework for Cooperative Aerial Manipulation of Cable-Suspended Payloads
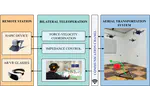
This project builds a visual impedance teleoperation framework that lets a human operator feel and steer cooperative aerial manipulation of cable-suspended payloads.
Dec 5, 2024
Geometric Impedance Manipulation in Multi-Aerial Robot Systems with Cable-Suspended Loads
This project develops geometric impedance control on the SE(3) manifold for multi-robot aerial manipulation and physical human-robot interaction.
Dec 5, 2024
Cite
×