Research
Publications
People
News
Student Projects
Join Us
Wiki
Contact
Light
Dark
Automatic
Control
Safety-Critical Control of Quadrotors with High-Order Control Barrier Functions
This project develops high-order control barrier functions that account for actuator dynamics, keeping quadrotors safe during aggressive flight in clutter.
Jul 25, 2026
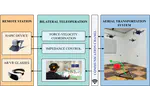
A Visual-Impedance Teleoperation Framework for Cooperative Aerial Manipulation of Cable-Suspended Payloads
This project builds a visual impedance teleoperation framework that lets a human operator feel and steer cooperative aerial manipulation of cable-suspended payloads.
Dec 5, 2024
Enhancing Disturbance Rejection in Multi-Aerial Robot Systems with Cable-Suspended Loads
This project develops differential cable force allocation to improve disturbance rejection in teams of aerial robots carrying cable-suspended loads.
Dec 5, 2024
Geometric Impedance Manipulation in Multi-Aerial Robot Systems with Cable-Suspended Loads
This project develops geometric impedance control on the SE(3) manifold for multi-robot aerial manipulation and physical human-robot interaction.
Dec 5, 2024
Learning Contraction Metrics for Robust Control of Hybrid Aerial Robots with Suspended Payloads
This project learns contraction metrics for robust control of hybrid aerial robots with suspended payloads.
Dec 5, 2024
Cite
×