Multi-Robot Collaboration
Research pillar
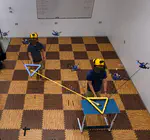
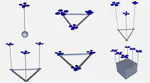
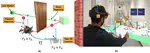
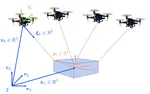
Teams of aerial robots can move objects that no single vehicle could lift, self-assemble into new structures, and coordinate with people. This pillar covers cooperative transportation and manipulation with multiple quadrotors, modular self-assembling aerial systems, decentralized planning and collision avoidance, relative perception between robots, and human-multi-robot collaboration.