Aerial Robot Agility, Intelligence and Safety
Research pillar
Agile flight demands controllers, planners, and perception pipelines that run fast, exploit the full dynamics of the vehicle, and stay safe under uncertainty, rotor failures, and degraded sensing. This pillar covers our work on nonlinear and learning-based model predictive control, perception-aware and safety-constrained planning, state estimation and mapping, fault-tolerant control, and formal safety guarantees for quadrotors.
Journal Articles
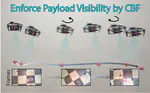
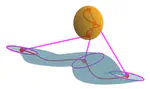
PolyFly: Polytopic Optimal Planning for Collision-Free Cable-Suspended Aerial Payload Transportation
IEEE Robotics and Automation Letters