Aerial Physical Intelligence
Research pillar
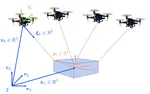
Aerial robots become far more useful when they can touch, carry, and manipulate the world. This pillar covers cable-suspended payload transportation, aerial manipulation, contact-rich tasks such as perching and tactile contour following, and physically collaborative interaction with people, together with the simulators and control frameworks that make these behaviors reliable.
Journal Articles
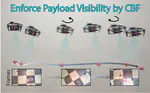
PolyFly: Polytopic Optimal Planning for Collision-Free Cable-Suspended Aerial Payload Transportation
IEEE Robotics and Automation Letters