Geometric Impedance Manipulation in Multi-Aerial Robot Systems with Cable-Suspended Loads
 None.
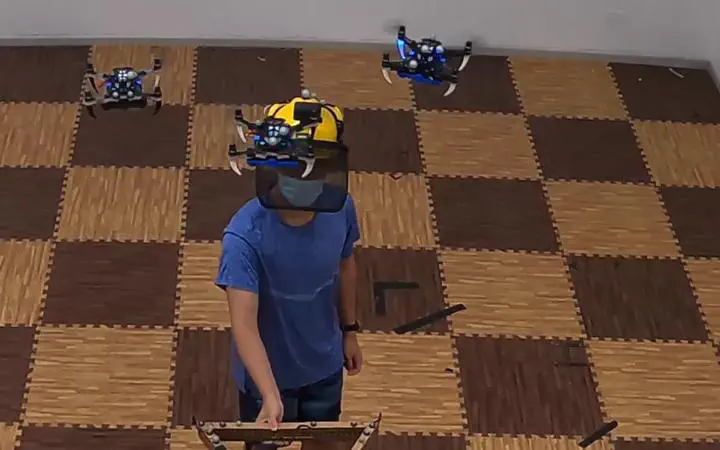
This research explores advanced control strategies for human-robot interactions, focusing on a geometric impedance controller on the SE(3) manifold to address the coupling of translational and rotational dynamics in complex motions.