Enhancing Disturbance Rejection in Multi-Aerial Robot Systems with Cable-Suspended Loads
 None.
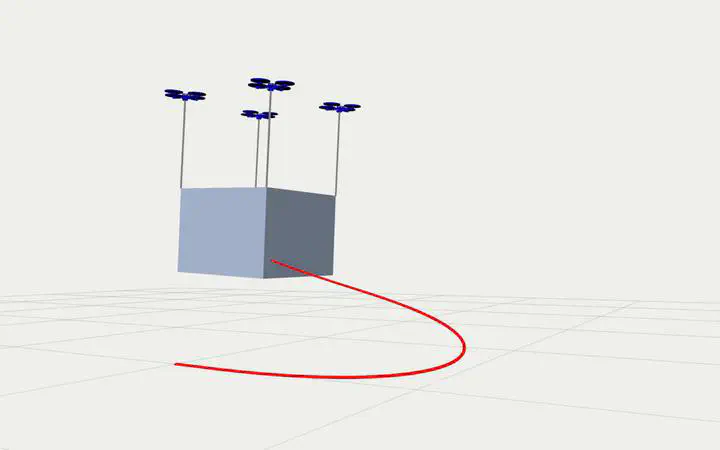
The use of a cable force allocation matrix has proven beneficial for human-payload interaction and for maintaining safe robot separation, without compromising payload trajectory tracking. However, there is a lack of studies on the differential cable force allocation matrix, which could further maximize dynamic manipulability and increase disturbance rejection.