Student Projects
Open projects for WPI students. Filter by topic and click a card to read the details and desired skills.
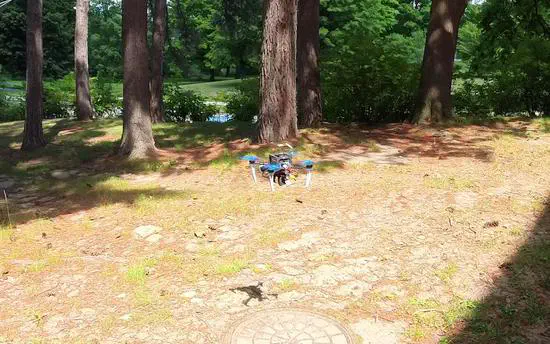
VLM-Guided Semantic Safety for Onboard Aerial Autonomy
This project uses vision-language models to give aerial robots onboard semantic safety awareness. Our first paper on this topic was accepted at two IROS 2026 workshops.
Rust for Robotics on Aerial Systems
This project explores Rust as a language for safe and performant robotics software on aerial robots. It connects directly to the Why Rust for Robotics workshop that our lab led at IROS 2026.

Safety-Critical Control of Quadrotors with High-Order Control Barrier Functions
This project develops high-order control barrier functions that account for actuator dynamics, keeping quadrotors safe during aggressive flight in clutter.
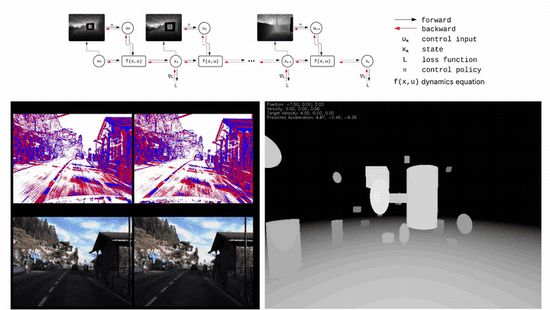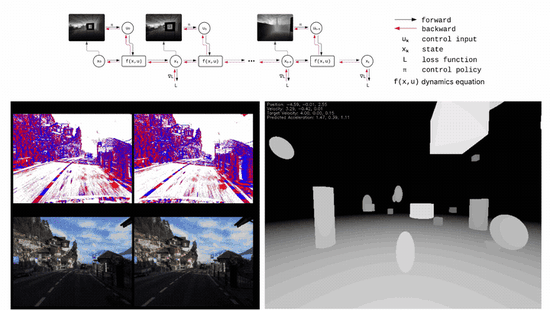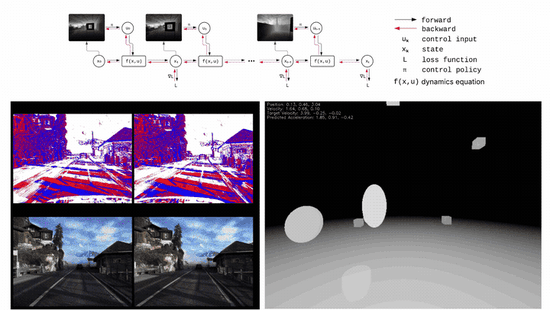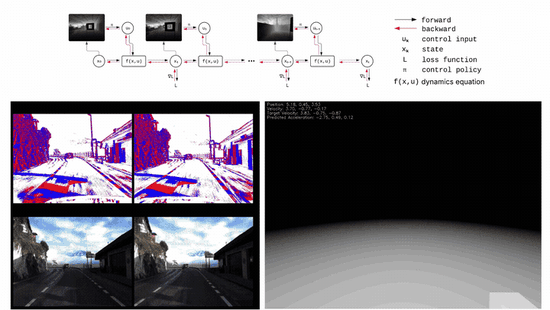
Learning agile flights in clustered environments for quadrotors from pixel information using differentiable simulators and novel sensors
This project teaches quadrotors agile flight in cluttered and visually degraded environments directly from pixels, using differentiable simulators and novel sensors.
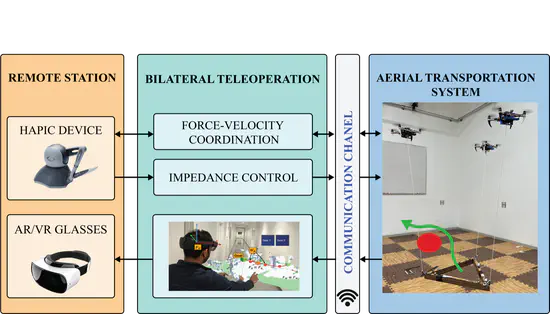
A Visual-Impedance Teleoperation Framework for Cooperative Aerial Manipulation of Cable-Suspended Payloads
This project builds a visual impedance teleoperation framework that lets a human operator feel and steer cooperative aerial manipulation of cable-suspended payloads.
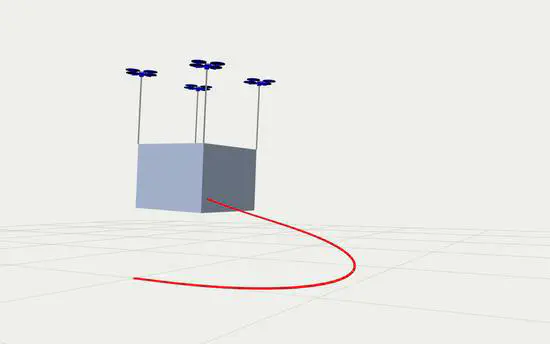
Enhancing Disturbance Rejection in Multi-Aerial Robot Systems with Cable-Suspended Loads
This project develops differential cable force allocation to improve disturbance rejection in teams of aerial robots carrying cable-suspended loads.
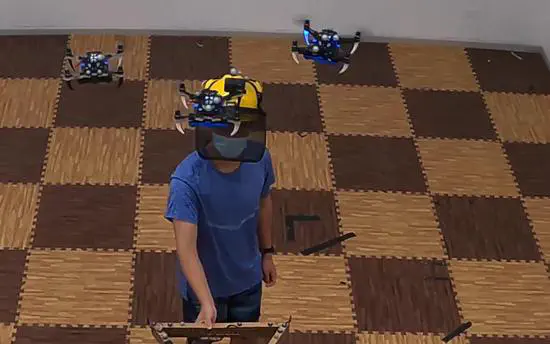
Geometric Impedance Manipulation in Multi-Aerial Robot Systems with Cable-Suspended Loads
This project develops geometric impedance control on the SE(3) manifold for multi-robot aerial manipulation and physical human-robot interaction.
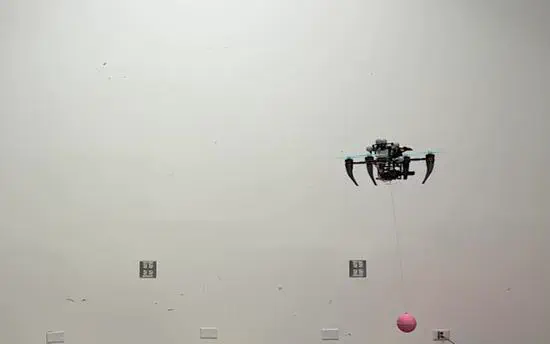
Learning Contraction Metrics for Robust Control of Hybrid Aerial Robots with Suspended Payloads
This project learns contraction metrics for robust control of hybrid aerial robots with suspended payloads.