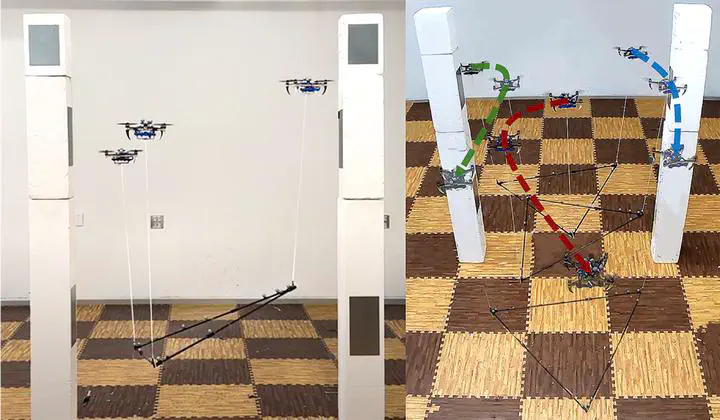
Optimal Trajectory Planning for Cooperative Manipulation with Multiple Quadrotors Using Control Barrier FunctionsArpan Pallar, Guanrui Li, Mrunal Sarvaiya, Giuseppe Loianno Aerial Physical Intelligence, Multi-Robot CollaborationGuanrui LiAssistant Professor in Robotics Engineering