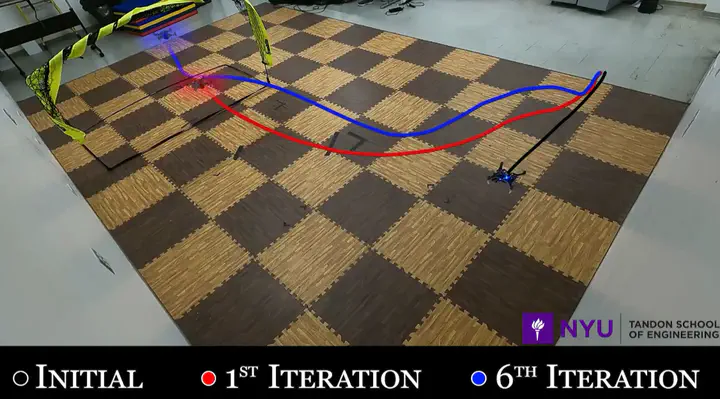
Learning Model Predictive Control for QuadrotorsGuanrui Li, Alex Tunchez, Giuseppe Loianno Agility, Intelligence and SafetyPDF Cite VideoGuanrui LiAssistant Professor in Robotics Engineering