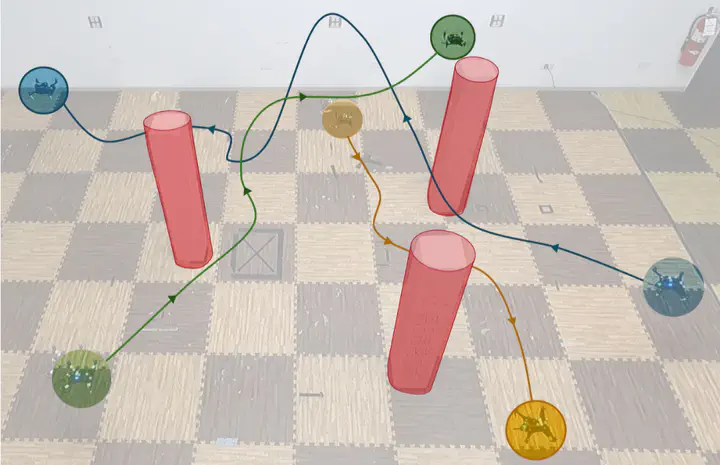
Decentralized Nonlinear Model Predictive Control for Safe Collision Avoidance in Quadrotor Teams with Limited Detection RangeManohari Goarin, Guanrui Li, Alessandro Saviolo, Giuseppe Loianno Agility, Intelligence and Safety, Multi-Robot CollaborationPDF Cite VideoGuanrui LiAssistant Professor in Robotics Engineering