News
People
Research
Publications
Gallery
Student Projects
Wiki
Contact
Agility, Intelligence and Safety
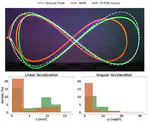
Physics-Inspired Temporal Learning of Quadrotor Dynamics for Accurate Model Predictive Trajectory Tracking
IEEE Robotics and Automation Letters (RA-L)
, 2022
Alessandro Saviolo
,
Guanrui Li
,
Giuseppe Loianno
Agility, Intelligence and Safety
PDF
Cite
Video
Vision-based Relative Detection and Tracking for Teams of Micro Aerial Vehicles
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
,2022
Rundong Ge
,
Moonyoung Lee
,
Vivek Radhakrishnan
,
Yang Zhou
,
Guanrui Li
,
Giuseppe Loianno
Agility, Intelligence and Safety
,
Multi-Robot Collaboration
PDF
Cite
Video
Aggressive Visual Perching with Quadrotors on Inclined Surfaces
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
, 2021
Jeffrey Mao
,
Guanrui Li
,
Stephen Nogar
,
Christopher Kroninger
,
Giuseppe Loianno
Agility, Intelligence and Safety
,
Aerial Physical Intelligence
PDF
Cite
Video
PCMPC: Perception-Constrained Model Predictive Control for Quadrotors with Suspended Loads using a Single Camera and IMU
IEEE International Conference on Robotics and Automation (ICRA)
, 2021
Guanrui Li
,
Alex Tunchez
,
Giuseppe Loianno
Agility, Intelligence and Safety
,
Aerial Physical Intelligence
PDF
Cite
Video
Efficient Trajectory Library Filtering for Quadrotor Flight in Unknown Environments
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
, 2020
Vaibhav K Viswanathan
,
Eric Dexheimer
,
Guanrui Li
,
Giuseppe Loianno
,
Michael Kaess
,
Sebastian Scherer
Agility, Intelligence and Safety
PDF
Cite
Video
Observability-Aware Trajectories for Geometric and Inertial Self-Calibration
Robotics: Science and Systems: Power On And Go Robots Workshop
, 2020
Christoph Bohm
,
Guanrui Li
,
Giuseppe Loianno
,
Stephan Weiss
Agility, Intelligence and Safety
PDF
Cite
«
Cite
×