Research
Publications
People
News
Student Projects
Join Us
Wiki
Contact
Light
Dark
Automatic
Agility, Intelligence and Safety
ClearNav: Perception-Aligned Quadrotor Flight Using Differential-Physics
arXiv preprint
, 2026
Aditya Azad
,
Arthur Huang
,
Guanrui Li
Agility, Intelligence and Safety
PDF
Cite
Code
Project
Video
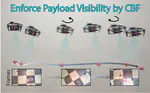
Safety-Critical Quadrotor Navigation Using Fourth-Order Control Barrier Functions with Full Nonlinear Quadrotor Dynamics
arXiv preprint
, 2026
Yanze Liu
,
Yaşar İdikut
,
Dhruv Madhusudan Agrawal
,
Wei Xiao
,
Guanrui Li
Agility, Intelligence and Safety
PDF
Cite
Video
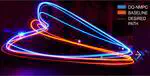
DQ-MPCC: Dual-Quaternion MPCC for Quadrotor Racing
arXiv preprint
, 2026
Bryan S. Guevara
,
Luis Fernando Recalde
,
Guanrui Li
,
Tiago Nascimento
Agility, Intelligence and Safety
PDF
Cite
Trajectory Planning Using Safe Ellipsoidal Corridors as Projections of Orthogonal Trust Regions
International Conference on Robotics and Automation (ICRA)
, 2026
Akshay Jaitly
,
Jon Arrizabalaga
,
Guanrui Li
Agility, Intelligence and Safety
PDF
Cite
ES-HPC-MPC: Exponentially Stable Hybrid Perception Constrained MPC for Quadrotor with Suspended Payloads
IEEE Robotics and Automation Letters (RA-L)
, 2025
Luis Fernando Recalde
,
Mrunal Sarvaiya
,
Giuseppe Loianno
,
Guanrui Li
Agility, Intelligence and Safety
,
Aerial Physical Intelligence
PDF
Cite
Project
Video
PolyFly: Polytopic Optimal Planning for Collision-Free Cable-Suspended Aerial Payload Transportation
IEEE Robotics and Automation Letters (RA-L)
, 2025
Mrunal Sarvaiya
,
Guanrui Li
,
Giuseppe Loianno
Oct 17, 2025
Agility, Intelligence and Safety
,
Aerial Physical Intelligence
PDF
Cite
Project
Video
Source Document
DQ-NMPC: Dual-Quaternion NMPC for Quadrotor Flight
IEEE Robotics and Automation Letters (RA-L)
, 2025
Luis Fernando Recalde
,
Dhruv Madhusudan Agrawal
,
Jon Arrizabalaga
,
Guanrui Li
Agility, Intelligence and Safety
PDF
Cite
Code
Project
Video
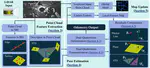
DualQuat-LOAM LiDAR Odometry and Mapping parametrized on Dual Quaternions
Robotics and Autonomous Systems
, 2025
Edison P. Velasco-Sanchez
,
Luis Fernando Recalde
,
Guanrui Li
,
Francisco A. Candelas-Herias
,
Santiago T. Puente-Mendez
,
Fernando Torres-Medina
Agility, Intelligence and Safety
PDF
Cite
Code
Project
Video
Decentralized Nonlinear Model Predictive Control for Safe Collision Avoidance in Quadrotor Teams with Limited Detection Range
International Conference on Robotics and Automation (ICRA)
, 2025
Manohari Goarin
,
Guanrui Li
,
Alessandro Saviolo
,
Giuseppe Loianno
Agility, Intelligence and Safety
,
Multi-Robot Collaboration
PDF
Cite
Video
Experimental System Design of an Active Fault-Tolerant Quadrotor
International Conference on Unmanned Aircraft Systems (ICUAS)
, 2024
Jennifer Yeom
,
Roshan Balu T M B
,
Guanrui Li
,
Giuseppe Loianno
Agility, Intelligence and Safety
PDF
Cite
»
Cite
×