News
People
Research
Publications
Gallery
Student Projects
Wiki
Contact
Aerial Physical Intelligence
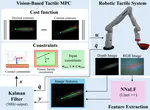
VBT-MPC: Vision-Based Tactile MPC for Contour Following
IEEE Robotics and Automation Letters (RA-L)
, 2026
Edison P. Velasco-Sanchez
,
Luis F. Recalde
,
Guanrui Li
,
Pablo Gil
Aerial Physical Intelligence
PDF
Cite
Code
Project
Video
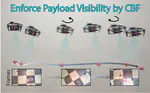
ES-HPC-MPC: Exponentially Stable Hybrid Perception Constrained MPC for Quadrotor with Suspended Payloads
IEEE Robotics and Automation Letters (RA-L)
, 2025
Luis F. Recalde
,
Mrunal Sarvaiya
,
Giuseppe Loianno
,
Guanrui Li
Agility, Intelligence and Safety
,
Aerial Physical Intelligence
PDF
Cite
Project
Video
PolyFly: Polytopic Optimal Planning for Collision-Free Cable-Suspended Aerial Payload Transportation
IEEE Robotics and Automation Letters
Mrunal Sarvaiya
,
Guanrui Li
,
Giuseppe Loianno
Oct 17, 2025
Agility, Intelligence and Safety
,
Aerial Physical Intelligence
PDF
Cite
Project
Video
Source Document
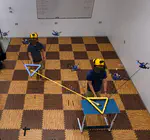
Human-Aware Physical Human-Robot Collaborative Transportation and Manipulation with Multiple Aerial Robots
IEEE Transactions on Robotics (T-RO)
, 2025
Guanrui Li
,
Xinyang Liu
,
Giuseppe Loianno
Aerial Physical Intelligence
,
Multi-Robot Collaboration
PDF
Cite
Video
Optimal Trajectory Planning for Cooperative Manipulation with Multiple Quadrotors Using Control Barrier Functions
IEEE International Conference on Robotics and Automation (ICRA)
, 2025
Arpan Pallar
,
Guanrui Li
,
Mrunal Sarvaiya
,
Giuseppe Loianno
Aerial Physical Intelligence
,
Multi-Robot Collaboration
HPA-MPC: Hybrid Perception-Aware Nonlinear Model Predictive Control for Quadrotors with Suspended Loads
IEEE Robotics and Automation Letters (RA-L)
, 2024
Mrunal Sarvaiya
,
Guanrui Li
,
Giuseppe Loianno
Agility, Intelligence and Safety
,
Aerial Physical Intelligence
PDF
Cite
Project
Video
RotorTM: A Flexible Simulator for Aerial Transportation and Manipulation
IEEE Transactions on Robotics (T-RO)
, 2024
Guanrui Li
,
Xinyang Liu
,
Giuseppe Loianno
Aerial Physical Intelligence
,
Multi-Robot Collaboration
PDF
Cite
Code
Video
Nonlinear Model Predictive Control for Cooperative Transportation and Manipulation of Cable Suspended Payloads with Multiple Quadrotors
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
, 2023
Guanrui Li
,
Giuseppe Loianno
Aerial Physical Intelligence
,
Multi-Robot Collaboration
PDF
Cite
Video
Aggressive Visual Perching with Quadrotors on Inclined Surfaces
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
, 2021
Jeffrey Mao
,
Guanrui Li
,
Stephen Nogar
,
Christopher Kroninger
,
Giuseppe Loianno
Agility, Intelligence and Safety
,
Aerial Physical Intelligence
PDF
Cite
Video
Cooperative Transportation of Cable Suspended Payloads With MAVs Using Monocular Vision and Inertial Sensing
IEEE Robotics and Automation Letters (RA-L)
, 2021
Guanrui Li
,
Rundong Ge
,
Giuseppe Loianno
Aerial Physical Intelligence
,
Multi-Robot Collaboration
PDF
Cite
Video
»
Cite
×