Worcester Polytechnic Institute
Aerial-robot Control and Perception Lab
We develop the planning, control, perception, and learning that let flying robots navigate the world, interact with it physically, and collaborate with other robots and people.
Three Research Pillars
Click a pillar to explore the related publications.
Recent News
Featured Publications
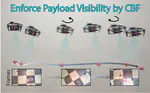
PolyFly: Polytopic Optimal Planning for Collision-Free Cable-Suspended Aerial Payload Transportation
IEEE Robotics and Automation Letters (RA-L), 2025
Our Sponsors
We gratefully acknowledge the support of our sponsors.